PX4 Timestamp
R2026bPX4 Timestamp block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
UAV Toolbox Support Package for PX4 Autopilots /
PX4 Utility Blocks
Description
Add-On Required: This feature requires the UAV Toolbox Support Package for PX4 Autopilots add-on.
The PX4 timestamp block gets the time since start in microseconds from
the PX4 Autopilot into the Simulink® Model. This timestamp information is absolute, ensuring it never wraps or
goes backwards. The output datatype of timestamp is uint64.
Examples
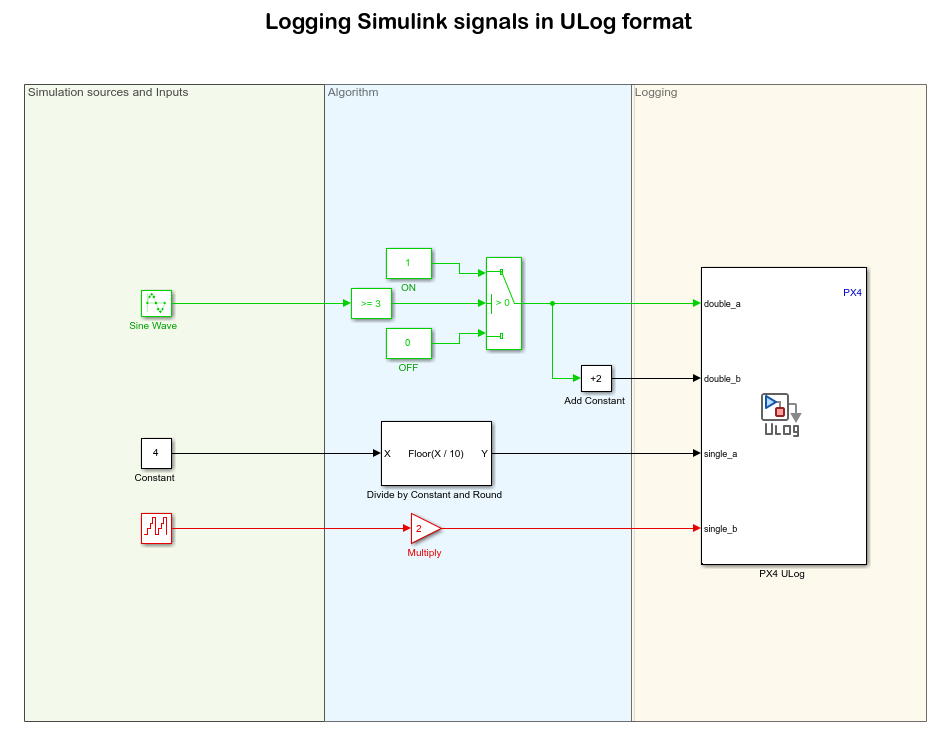
Log Simulink Signals Using PX4 ULog
Log signals in ULog format from a Simulink® model running on a Pixhawk® hardware and retrieve the log files from the SD card for further analysis.
Ports
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"px4Utilslib/PX4 Write Thrust & Torque Setpoint"
Example: add_block("px4Utilslib/PX4 Write Thrust & Torque Setpoint","myModel/myBlock",MakeNameUnique="on")
Version History
Introduced in R2023b

