Read Parameter
R2026bRead PX4 system parameters
Read Parameter block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
UAV Toolbox Support Package for PX4 Autopilots /
PX4 Utility Blocks
Description
Add-On Required: This feature requires the UAV Toolbox Support Package for PX4 Autopilots add-on.
The Read Parameter block reads the specified PX4 system parameter, and provides its value as output.
The block supports all parameters listed in PX4 Parameter Reference page. You can also use custom parameters that you define by following the guidelines.
During Normal mode simulation, the block outputs zeroes.
During Connected I/O simulation, this block reads data from the peripherals of the hardware.
Examples
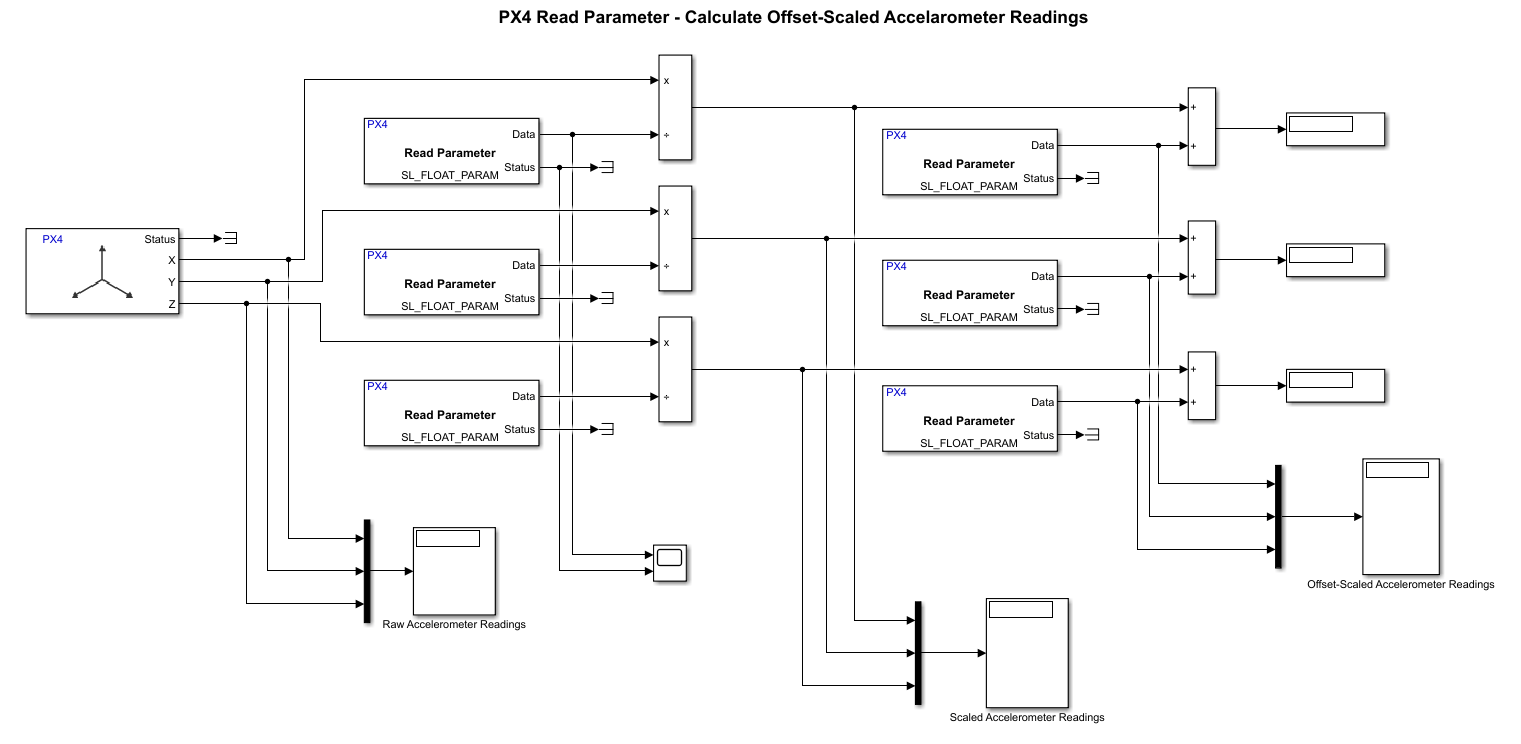
Read PX4 System Parameters from PX4 Autopilot
Read system parameters from PX4® autopilot using Read Parameter block.
Ports
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"px4Utilslib/Read Parameter"
Example: add_block("px4Utilslib/Read Parameter","myModel/myBlock",MakeNameUnique="on")
Version History
Introduced in R2018b

