poseplot
R2026b3-D pose plot
Syntax
Description
The poseplot function plots a specified 3-D pose (position
and orientation) as a patch with an xyz-frame at the patch origin. The
poseplot function can plot a single or multiple 3-D
poses.
poseplot plots the pose at the coordinate origin position with zero
rotation. The default navigation frame is the north-east-down (NED) frame.
poseplot( plots the pose with the
specified orientation. The position by default is orientation)[0 0 0]. To plot
multiple poses, specify orientation as an array.
poseplot(___, specifies
the position of the pose plot. To plot multiple poses, specify position)position
as a matrix.
poseplot(___, specifies the
navigation frame of the pose plot. frame)
poseplot(___, specifies
pose patch properties using one or more name-value arguments. The properties apply to all
the plotted poses. For example, Name=Value)poseplot(FaceColor="r") plots the pose
with red face color. For a list of properties, see PosePatch Properties.
poseplot( specifies the
parent axes of the pose plot.ax,___)
p = poseplot(___)PosePatch object or an array of PosePatch objects.
Use p to modify properties of the pose plot after creation. For a list of
properties, see PosePatch Properties.
Examples
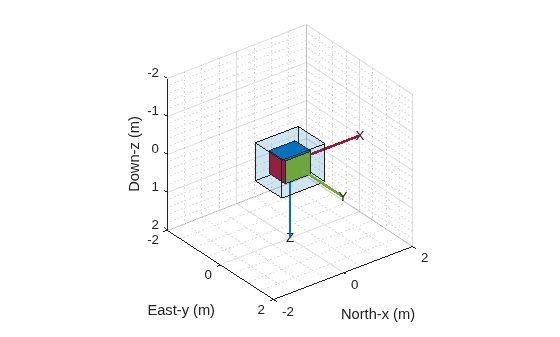
Plot the default pose using the poseplot function with default settings.
poseplot
xlabel("North-x (m)")
ylabel("East-y (m)")
zlabel("Down-z (m)");
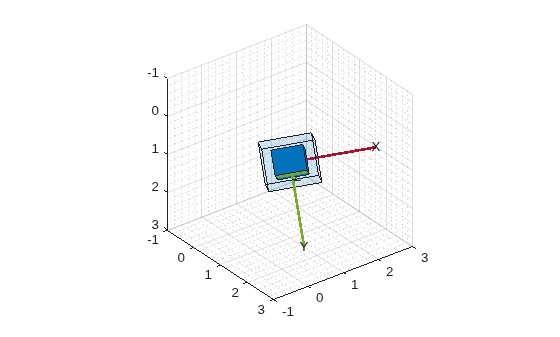
Next, plot a pose with specified orientation and position.
q = quaternion([35 10 50],"eulerd","ZYX","frame");
position = [1 1 1];
poseplot(q,position)
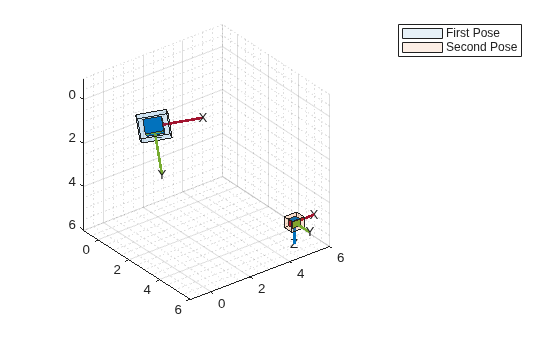
Then, plot a second pose on the figure and return the PosePatch object. Plot the second pose with a smaller size by using the ScaleFactor name-value argument.
hold on
p = poseplot(eye(3),[5 5 5],ScaleFactor=0.5)
p =
PosePatch with properties:
Orientation: [3×3 double]
Position: [5 5 5]
Show all properties
legend("First Pose","Second Pose")
hold off
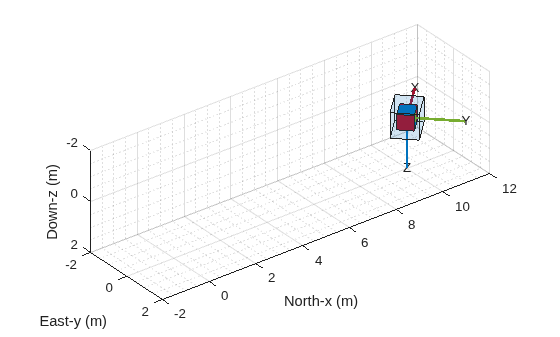
Animate a series of poses using the poseplot function. First, define the initial and final positions.
ps = [0 0 0];
pf = [10 0 0];
Then, define the initial and final orientations using the quaternion object.
qs = quaternion([45,0,0],'eulerd','ZYX','frame');
qf = quaternion([-45,0,0],'eulerd','ZYX','frame');
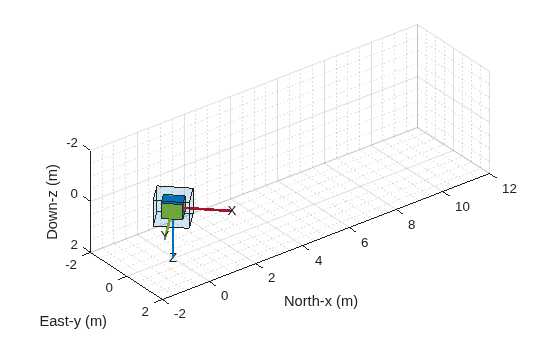
Show the starting pose.
patch = poseplot(qs,ps);
ylim([-2 2])
xlim([-2 12])
xlabel("North-x (m)")
ylabel("East-y (m)")
zlabel("Down-z (m)");
Change the position and orientation continuously using coefficients, and update the pose using the set object function.
for coeff = 0:0.01:1
    q = slerp(qs,qf,coeff);
    position = ps + (pf - ps)*coeff;
    set(patch,Orientation=q,Position=position);
    drawnow
end
Plot multiple poses in a single call to the poseplot function, then hide the pose axis labels and origin boxes to reduce visual clutter.
Define 10 poses along a spiral trajectory. Create a 10-by-3 matrix of positions and a 10-by-1 array of quaternion orientations that rotate to follow the path.
numPoses = 10;
t = linspace(0,2*pi,numPoses)';
positions = [5*cos(t),5*sin(t),2*t];
orientations = quaternion([t+pi/2,zeros(numPoses,1),zeros(numPoses,1)],"euler","ZYX","frame");
Plot all 10 poses in a single call. By default, the poseplot function draws an origin box and pose axis labels at every pose, which can make a plot of many poses look cluttered.
figure
p1 = poseplot(orientations,positions);
axis equal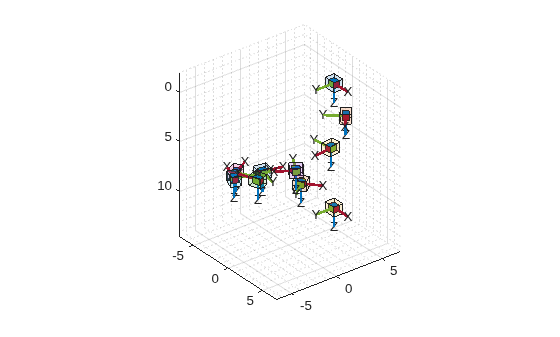
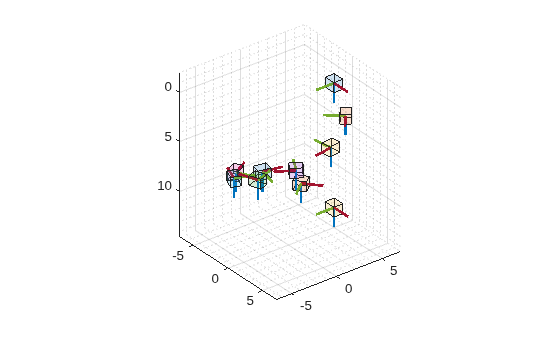
Reduce the clutter by hiding the pose axis labels and origin boxes. Set the PoseAxisLabels and OriginBox properties to "off". Plot the poses in a new figure to compare the result with the previous plot.
figure
p2 = poseplot(orientations,positions,PoseAxisLabels="off",OriginBox="off");
axis equal
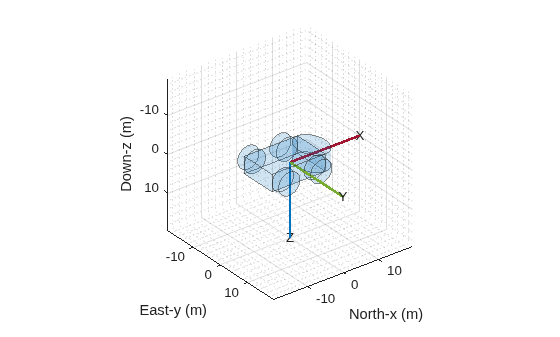
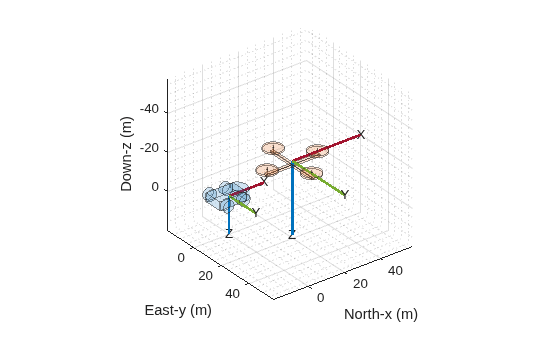
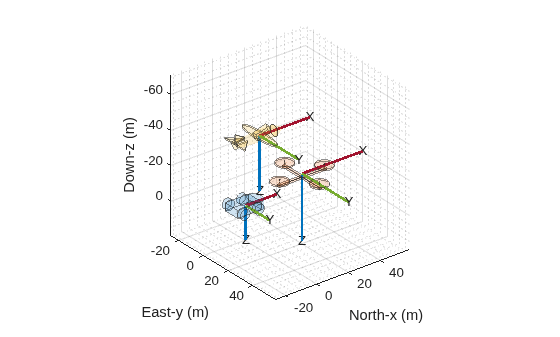
Plot orientations and positions in meshes using the poseplot function. First, plot a ground vehicle at the origin with zero rotation.
poseplot(ones("quaternion"),[0 0 0],MeshFileName="groundvehicle.stl",ScaleFactor=0.3);
xlabel("North-x (m)")
ylabel("East-y (m)")
zlabel("Down-z (m)")
Second, plot a rotor at the position [20 20 -20] with zero rotation.
hold on
poseplot(ones("quaternion"),[20 20 -20],MeshFileName="multirotor.stl",ScaleFactor=0.2);
Lastly, plot a fixed-wing aircraft at the position [5 5 -40] with zero rotation.
poseplot(ones("quaternion"),[5 5 -40],MeshFileName="fixedwing.stl",ScaleFactor=0.4);
view([-37.8 28.4])
hold off
Input Arguments
Name-Value Arguments
Specify optional pairs of arguments as
Name1=Value1,...,NameN=ValueN, where Name is
the argument name and Value is the corresponding value.
Name-value arguments must appear after other arguments, but the order of the
pairs does not matter.
Example: poseplot(FaceAlpha=0.1)
The PosePatch properties listed here are only a subset. For a
complete list, see PosePatch Properties.
Orientation of the pose plot, specified as a quaternion (Sensor Fusion and Tracking Toolbox)
object or a rotation matrix.
Position of the pose plot, specified as a three-element real-valued vector.
This property is read-only after object creation.
Name of Standard Triangle Language (STL) mesh file, specified as a string scalar or a
character vector containing the name of the mesh file. When you
specify this argument, the poseplot
function plots the mesh instead of the orientation box.
Scale factor of the pose plot, specified as a nonnegative scalar. The scale factor
controls the size of the orientation box. When you specify the
MeshFileName argument, the scale factor also changes the scale
of the mesh.
Face color of pose patch, specified as an RGB triplet, a hexadecimal color code, a color name, or a short name.
An RGB triplet is a three-element row vector whose elements specify the intensities of the red, green, and blue components of the color. The intensities must be in the range
[0, 1]; for example,[0.4 0.6 0.7].A hexadecimal color code is a character vector or a string scalar that starts with a hash symbol (
#) followed by three or six hexadecimal digits, which can range from0toF. The values are not case sensitive. Thus, the color codes"#FF8800","#ff8800","#F80", and"#f80"are equivalent.
The default value is an RGB triplet from the ColorOrder property of
the axes. The SeriesIndex property of the
PosePatch object determines which color from the
ColorOrder the pose plot uses.
Here is a list of commonly used colors and their corresponding values.
| Color Name | Short Name | RGB Triplet | Hexadecimal Color Code | Appearance |
|---|---|---|---|---|
"red" | "r" | [1 0 0] | "#FF0000" |
|
"green" | "g" | [0 1 0] | "#00FF00" |
|
"blue" | "b" | [0 0 1] | "#0000FF" |
|
"cyan"
| "c" | [0 1 1] | "#00FFFF" |
|
"magenta" | "m" | [1 0 1] | "#FF00FF" |
|
"yellow" | "y" | [1 1 0] | "#FFFF00" |
|
"black" | "k" | [0 0 0] | "#000000" |
|
"white" | "w" | [1 1 1] | "#FFFFFF" |
|


Face transparency of pose patch, specified as a scalar in range [0,
1]. A value of 1 is fully opaque and
0 is completely transparent.
Since R2026b
This property is read-only after object creation.
Edge density of mesh, specified as a numeric scalar in the range [0,
1]. This property controls the density of edges displayed on a mesh specified
by MeshFileName.
A value of 0 hides all edges. A value of 1
displays all edges. Between 0 and 1, higher values
display more edges.
Setting this property has no effect if you do not specify
MeshFileName.
For more information about EdgeDensity, see the More About section.
Data Types: single | double
Since R2026b
Visibility of the origin box, specified as "on" or
"off", or as numeric or logical 1
(true) or 0 (false). A value of
"on" is equivalent to true, and
"off" is equivalent to false. Thus, you can use
the value of this property as a logical value. The value is stored as an on/off logical
value of type matlab.lang.OnOffSwitchState.
"on"— Display the box at the origin of the pose."off"— Hide the origin box. Use this option to improve plot visibility when displaying a large number of poses simultaneously.
Setting this property has no effect when you specify a mesh using
MeshFileName. Specifying MeshFileName hides the
origin box.
Since R2026b
Visibility of pose axis labels, specified as "on" or
"off", or as numeric or logical 1
(true) or 0 (false). A value of
"on" is equivalent to true, and
"off" is equivalent to false. Thus, you can use
the value of this property as a logical value. The value is stored as an on/off logical
value of type matlab.lang.OnOffSwitchState.
"on"— Display the X, Y, and Z axis labels at the tips of the pose axes."off"— Hide the axis labels. Use this option to improve plot visibility when displaying a large number of poses simultaneously.

