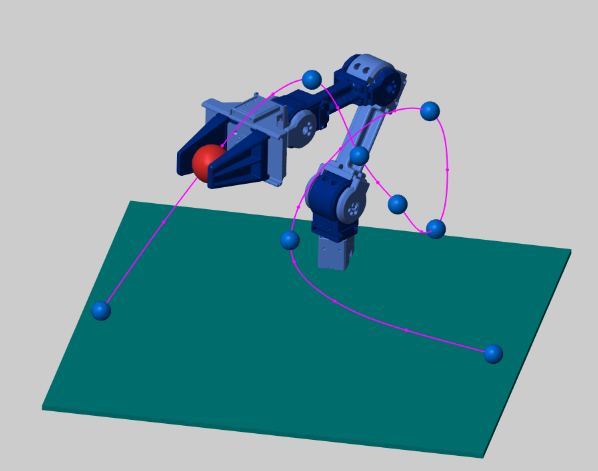
Designing Robot Manipulator Algorithms
MATLAB and Simulink files for modeling and simulation of ROBOTIS OpenManipulator
https://github.com/mathworks-robotics/designing-robot-manipulator-algorithms

You are now following this Submission
- You will see updates in your followed content feed
- You may receive emails, depending on your communication preferences
Cite As
MathWorks Student Competitions Team (2026). Designing Robot Manipulator Algorithms (https://github.com/mathworks-robotics/designing-robot-manipulator-algorithms), GitHub. Retrieved .
Acknowledgements
Inspired by: Simscape Multibody Multiphysics Library, Simscape Multibody Contact Forces Library
Inspired: Mass Estimation for Manipulators using Sliding Mode Observer
General Information
- Version 2.5.0 (1.05 MB)
-
 View License on GitHub
MATLAB Release Compatibility
- Compatible with R2019b and later releases
Platform Compatibility
- Windows
- macOS
- Linux
| Version | Published | Release Notes | Action |
|---|---|---|---|
| 2.5.0 | Linked to GitHub. Updated to use new built-in contact forces in Simscape Multibody. Switched from Curve Fitting Toolbox splines to Robotics System Toolbox for cubic and trapezoidal velocity trajectories. |
||
| 2.4.0 | Bug fixes due to changes in external robot description repository. |
||
| 2.3.0 | Upgraded models to R2018b. Now using the built-in Inverse Kinematics block in Robotics System Toolbox. |
||
| 2.2.0 | Minor updates due to robot description file changes in the ROBOTIS GitHub repository. |
||
| 2.1.0 | Bug fixes to check and resolve external file dependencies. Added preloaded MATLAB object as a backup in case external files cannot be set up correctly. |
||
| 2.0.0 | Added torque control examples, using the new R2018a Robotics System Toolbox blocks. |
||
| 1.0.0 | Adding a script to check necessary dependencies for submission |

