Structure from Motion
R2026bStructure from motion (SfM) is the process of estimating the 3-D structure of a scene from a set of 2-D images taken from different viewpoints. Computer Vision Toolbox™ provides an end-to-end SfM pipeline, including feature detection, matching, camera pose estimation, triangulation, and bundle adjustment. These capabilities are essential for applications such as 3-D mapping, photogrammetry, and autonomous navigation.
The toolbox provides a ready-to-run SfM pipeline through the sfm
object. Create an sfm
object with your images and camera intrinsics and use its object functions to
run the full reconstruction pipeline:
connectImagePairs— Build a view graph of visually similar imagesverifyImagePairs— Refine the view graph using geometric constraintstriangulateInitialViews— Select a robust initial view pair and triangulate the first 3-D pointsreconstruct— Incrementally process all remaining views and reconstruct the full 3-D scene
Use the poses, pointCloud, and plot functions to retrieve and visualize the results.
For a step-by-step comprehensive walkthrough of an incremental structure-from-motion pipeline, see the Structure from Motion from Multiple Views example. For information on how to use the sparse 3-D point cloud of a scene and generate a dense 3-D mesh, see the Dense 3-D Reconstruction of Asteroid Surface from Image Sequence example.
For dense reconstruction and novel view synthesis, the toolbox supports Neural
Radiance Fields (NeRF). Use the trainNerfacto function to train a NeRF model on your collection
of images and generate novel views. You can then use the point cloud to generate
a 3-D mesh using the pc2surfacemesh (Point Cloud Toolbox) function.
The toolbox supports 3-D scene reconstruction from multi-view images using the
MapAnything model. Use the mapanything object to create a pretrained MapAnything model and
then use the reconstruct function to perform 3-D scene reconstruction and
estimate the camera poses, intrinsic parameters, depth maps, and point clouds
for the images.
Functions
Topics
Basics
- Best Practices for 3-D Reconstruction Using Structure from Motion
Best practices for achieving reliable 3-D reconstructions with a structure from motion pipeline using thesfmobject. - What Is Structure from Motion?
Estimate three-dimensional structures from two-dimensional image sequences. - Coordinate Systems
Specify pixel indices, spatial coordinates, and 3-D coordinate systems. - Point Feature Types
Choose functions that return and accept points objects for several types of features. - Local Feature Detection and Extraction
Learn the benefits and applications of local feature detection and extraction.
Incremental Structure from Motion
- Structure from Motion from Multiple Views
Estimate 3-D structure of a scene from a set of 2-D views using incremental structure from motion. (Since R2026a) - Structure from Motion from Two Views
Estimate 3-D structure of a scene from a set of 2-D images.
Featured Examples
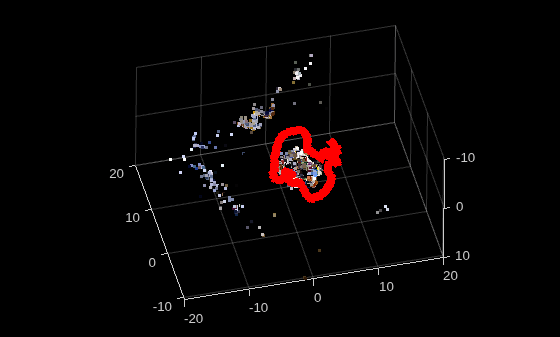
Structure from Motion from Multiple Views
Estimate 3-D structure of a scene from a set of 2-D views using incremental structure from motion.
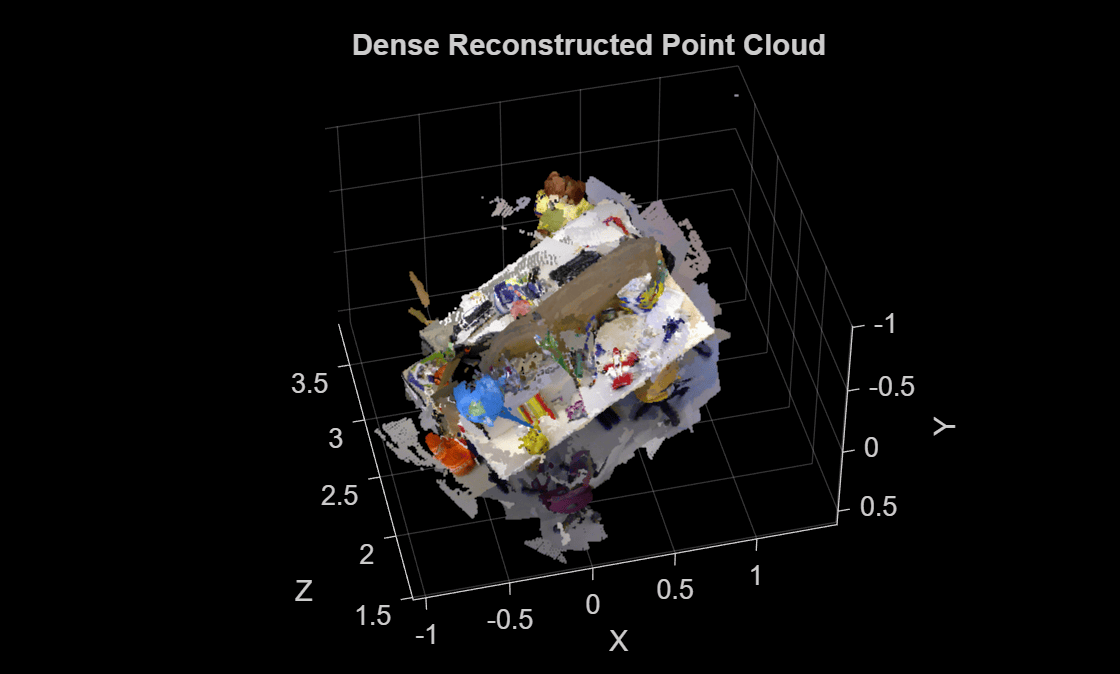
Dense 3-D Reconstruction from Multiple Views Using RAFT Optical Flow
Reconstruct dense 3-D scene by augmenting sparse Structure-from-Motion (SfM) point cloud with dense pixel correspondences estimated using RAFT optical flow.
Dense 3-D Reconstruction from Two Views Using RAFT Optical Flow
Perform dense 3-D scene reconstruction from two monocular images showing different viewpoints using RAFT optical flow model.
Dense 3-D Reconstruction of Asteroid Surface from Image Sequence
Reconstruct dense 3-D point cloud and continuous surface mesh for an asteroid using 2-D images.
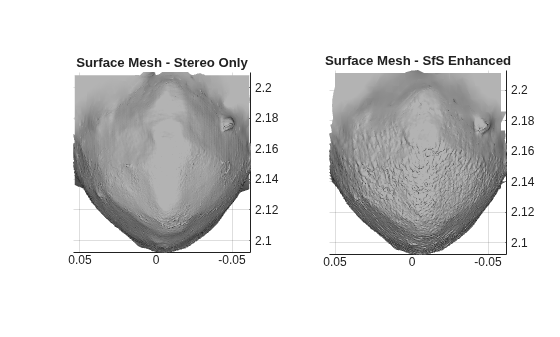
Reconstruct Detailed Surface Structure Using Shape from Shading
Add high-frequency surface detail to stereo depth maps using Shape from Shading (SfS).
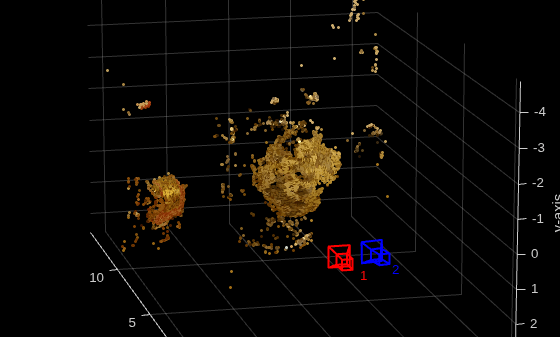
Structure from Motion from Two Views
Estimate 3-D structure of a scene from a set of 2-D images.
Reconstruct 3-D Scenes and Synthesize Novel Views Using Neural Radiance Field Model
Reconstruct 3-D scenes and synthesize novel views from a set of 2-D images using the Nerfacto Neural Radiance Field (NeRF) model.

